Compact Electric Parallel Gripper With Precise Object Handling, Serial Control And LEGO-Compatible Mounting
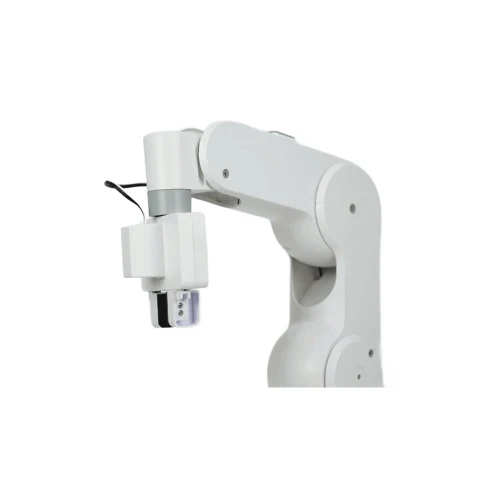
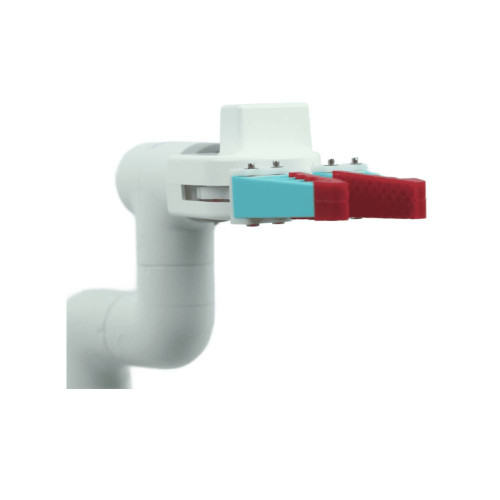
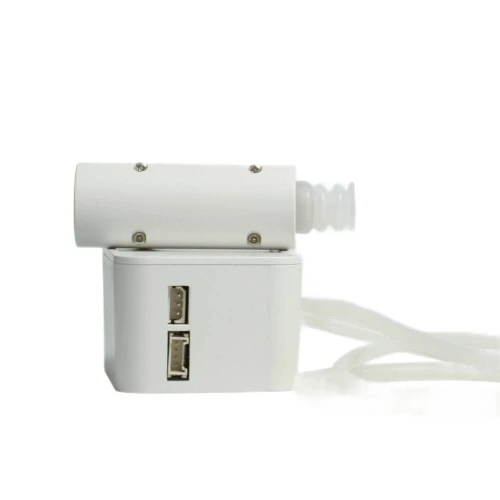
The Elephant Robotics myCobot Parallel Gripper is a compact electric end-effector designed for precise gripping and manipulation with compatible myCobot, myPalletizer, mechArm, and myBuddy robotic arms. Its parallel-finger mechanism maintains controlled fingertip movement for handling suitably sized objects in pick-and-place, sorting, assembly, inspection, education, and robotics-development applications.
The gripper uses an electric gear-and-linkage transmission with serial control, providing a simple integration path for supported Elephant Robotics platforms. It offers a clamp range of less than 20 mm, 80 g specified clamp force, and +/- 1 mm positioning precision. With a lightweight 90 g ABS structure and LEGO-compatible mounting interface, the gripper adds object-handling capability while keeping additional load on compact robotic arms relatively low.
Key Features
- Parallel Gripping Mechanism: Moves the gripping fingers in a controlled parallel configuration for precise object handling.
- Less Than 20 mm Clamp Range: Designed for gripping compatible small components and workpieces within the specified range.
- 80 g Clamp Force: Provides the manufacturer's specified gripping force for suitable lightweight objects.
- +/- 1 mm Positioning Precision: Supports repeatable gripping operations for educational, research, and automation applications.
- Electric Operation: Uses an electrically driven mechanism for automated opening and closing.
- Gear-And-Linkage Transmission: Provides controlled finger movement through an integrated mechanical transmission.
- Serial Control: Supports digital control from compatible Elephant Robotics robotic-arm platforms.
- Stable Object Handling: Parallel fingertip movement provides consistent contact with suitably shaped workpieces.
- Compact Construction: Measures only 66 x 78 x 46 mm for convenient integration with desktop robotic arms.
- Lightweight 90 g Design: Helps minimise the effect of the end effector on the robot's available payload.
- ABS Construction: Provides a lightweight housing suitable for robotics education and development.
- LEGO-Compatible Mounting: Simplifies mechanical attachment to supported Elephant Robotics platforms.
- Simple Installation: Compact construction and dedicated mounting simplify setup and maintenance.
- Fine Manipulation: Suitable for applications involving controlled gripping, placement, sorting, and inspection.
- Broad Robot Compatibility: Designed for selected myCobot 280, myPalletizer 260, mechArm 270, and myBuddy 280 platforms.
Applications
- Robotic pick-and-place
- Small-object handling
- Object sorting
- Assembly demonstrations
- Inspection applications
- Robotics education
- University laboratories
- Warehouse and logistics demonstrations
- Automated production-line experiments
- Automation prototyping
- Research robotics
- Maker projects
- Machine-vision sorting
- Component positioning
- End-effector development
- Lightweight material handling