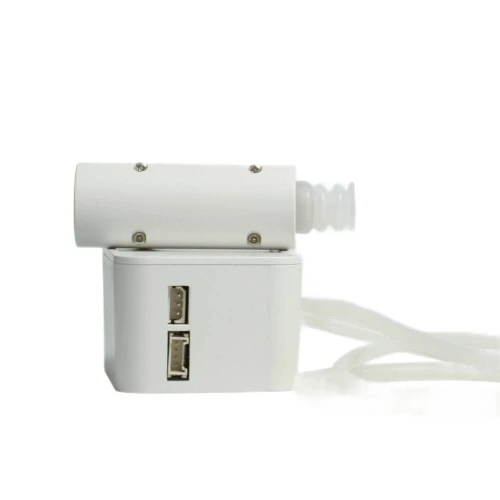
Flexible Electric Robot Gripper With Deformable Fingertips For Irregular And Curved Object Handling
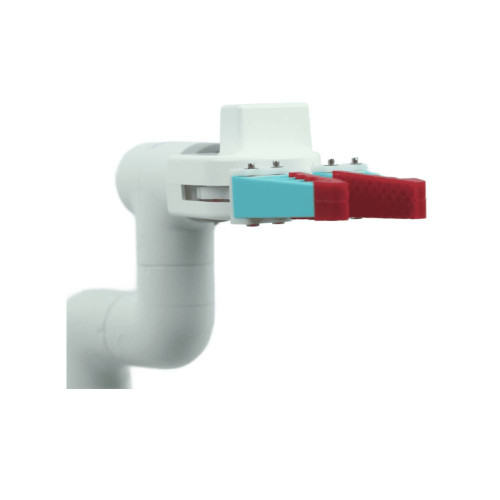
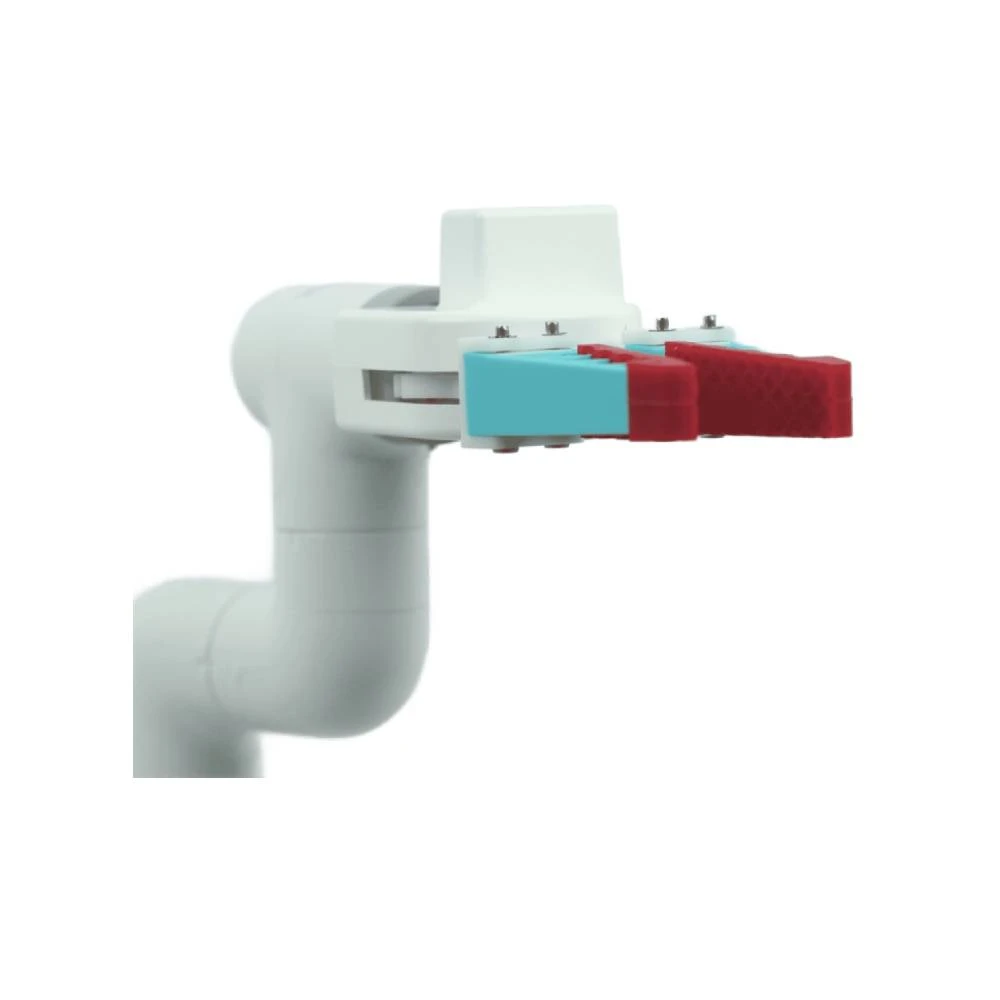
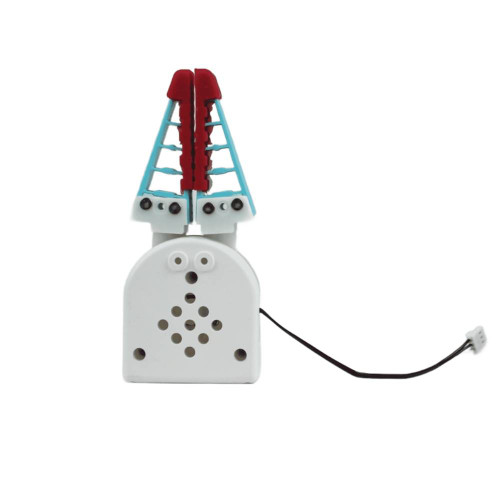
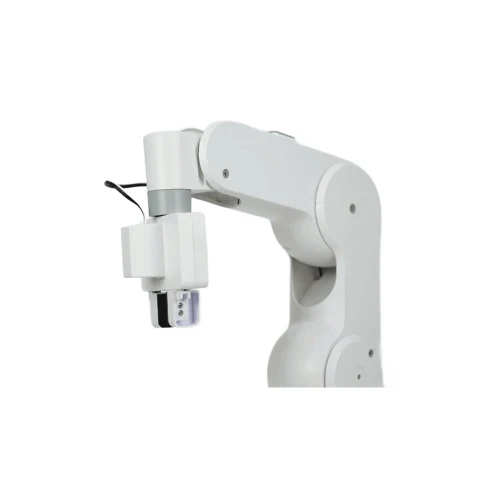
The myCobot Flexible Gripper from Elephant Robotics is an electric end-effector designed for compatible myCobot, myPalletizer, mechArm, and myBuddy robotic arms. Its flexible fingertip structure can deform around irregular, curved, and differently shaped objects, increasing the contact area between the gripper and workpiece. This makes it suitable for robotics education, object-handling experiments, automated sorting, research, and applications where rigid parallel gripping may not provide sufficient surface contact.
The gripper uses electric actuation with a gear-and-linkage transmission and serial control for integration with compatible Elephant Robotics platforms. Its adjustable gripping action allows the fingers to adapt to different object dimensions and surfaces, while the LEGO-compatible mounting interface simplifies attachment to supported robotic arms. With approximately 100 g weight and +/- 1 mm positioning precision, it provides a lightweight gripping option for desktop robotics and experimental automation systems.
Key Features
- Flexible Fingertip Design: Deformable contact surfaces adapt to irregular, curved, and differently shaped objects.
- Adaptive Object Handling: Larger contact area helps improve gripping stability compared with rigid fingertips for suitable objects.
- Adjustable Gripping Action: Gripper movement can be adjusted according to the shape and dimensions of the target object.
- Electric Operation: Uses an electrically driven mechanism for automated robotic gripping.
- Gear-And-Linkage Transmission: Provides mechanical actuation through an integrated gear and linkage system.
- Serial Control: Supports serial communication for control from compatible Elephant Robotics platforms.
- +/- 1 mm Positioning Precision: Supports repeatable gripper positioning for educational and automation applications.
- Approximately 100 g Weight: Lightweight construction reduces additional load on compact desktop robotic arms.
- LEGO-Compatible Mounting: Provides convenient mechanical installation on supported Elephant Robotics platforms.
- Irregular Object Compatibility: Suitable for handling balls, curved components, blocks, containers, and other compatible workpieces.
- Gentle Contact Surface: Flexible fingertips can reduce concentrated contact pressure on suitable objects.
- Robot Handling Applications: Suitable for pick-and-place, sorting, handling, and robotic manipulation experiments.
- Education and Research Ready: Provides a practical end-effector for learning robotic gripping, motion control, and automation.
- Broad Robot Compatibility: Supports selected myCobot 280, myPalletizer 260, mechArm 270, and myBuddy 280 platforms.
Applications
- Robotic pick-and-place
- Irregular object handling
- Object sorting
- Robotics education
- University laboratories
- Automation prototyping
- Robot handling experiments
- Curved surface gripping
- Lightweight material handling
- 3D printing workflows
- Research robotics
- Maker projects
- Human-robot interaction experiments
- End-effector development
- Automated production demonstrations