Resources:
Datasheet
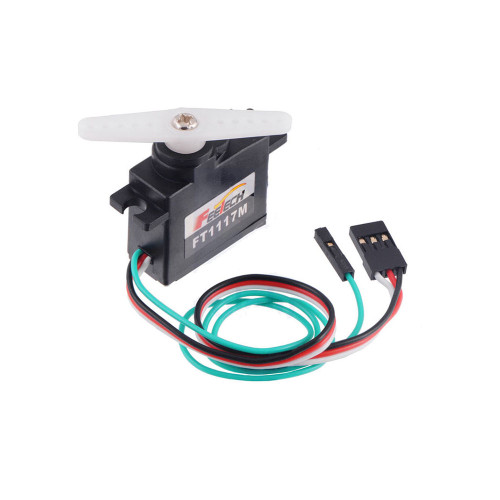
FT1117M-FB Compact Metal-Gear Analog Servo With 3.5 kgcm Torque, PWM Control and Direct Position Feedback
The FT1117M-FB is a compact analog PWM servo designed for robotics, RC systems, educational projects, embedded motion control, and applications requiring direct output-position monitoring. At 6V, it delivers up to 3.5 kg.cm stall torque with a no-load speed of 0.11 sec/60deg. The servo provides approximately 120deg of rated position control over a 900-2100us PWM command range, with a 1500us neutral position.
Unlike a conventional 3-wire RC servo, the FT1117M-FB provides an additional feedback wire connected to the internal potentiometer. This analog feedback allows a microcontroller or control system to monitor the actual output position independently of the commanded PWM signal. The servo combines a compact ABS housing, primarily metal gear train, core motor, 25T output spline, and approximately 22 g construction for robotic joints, sensor positioning, compact mechanisms, and higher-level closed-loop motion experiments.
Key Features
- 3.5 kg.cm Stall Torque at 6V: Provides useful torque for compact robotic mechanisms and RC applications.
- 3 kg.cm Stall Torque At 4.8V: Supports operation from standard 4.8V servo power systems.
- 120deg Rated Position Control: Provides approximately 120deg travel across the manufacturer's specified 900-2100us PWM range.
- 200deg Mechanical Limit: The underlying FT1117M mechanism has a specified physical limit of approximately 200deg.
- Analog Position Feedback: Dedicated feedback wire provides access to the internal position potentiometer.
- Standard PWM Control: Works with conventional RC servo PWM signals from compatible microcontrollers and servo controllers.
- 900-2100us Pulse Range: Manufacturer-specified PWM range for rated motion.
- 1500us Neutral Position: Provides a defined centre command for straightforward servo control.
- 0.11 sec/60deg At 6V: Offers responsive movement for compact robotics and positioning systems.
- 0.13 sec/60deg At 4.8V: Maintains controlled movement at the lower operating voltage.
- Analog Comparator Electronics: Uses analog servo-control electronics rather than a digital amplifier.
- Primarily Metal Gear Train: Most transmission gears are metal, while the input pinion gear is plastic.
- Core Motor: Uses a compact core motor for servo actuation.
- 25T Output Spline: Uses a standard-size 25T spline with approximately 5.8 mm diameter.
- ABS Case: Lightweight plastic housing supports compact installations.
- POM Servo Horn: Includes a plastic POM horn for compatible linkage connections.
- Compact Mini-Servo Size: Measures approximately 30 x 12 x 31.7 mm.
- Approximately 22 g Weight: Suitable for space- and weight-sensitive robotic systems.
- 2us Dead Band: Provides the specified narrow control dead-band width.
- Fourth Feedback Wire: Allows independent monitoring of the servo's physical output position.
Applications
- Compact robotic arms
- Educational robotics
- RC models
- Pan-and-tilt mechanisms
- Camera positioning
- Sensor positioning
- Embedded motion-control systems
- Position-feedback experiments
- Motion verification
- Obstruction detection
- Closed-loop robotics research
- Arduino projects
- ESP32 projects
- Raspberry Pi robotics
- Lightweight automation
- Maker projects
- Robotic joints
- Servo telemetry systems