Dispatch Update: Orders placed between 7 and 11 Nov may take up to 72 hours to dispatch due to Diwali holidays. Thank you for your patience.

4.8V 9kg.cm 1/320 Dual-axis TTL Serial Servo Motor 360deg Magnetic Encoding for Microduck

Feetech

No reviews yet Write a Review
SKU:
501-HD-1910-C001
MPN:
HD-1910-C001
4.8V 9kg.cm dual-axis TTL serial servo motor with 360-degree magnetic encoding, coreless motor and metal gears. Offers 0.088-degree resolution, multi-turn mode and full feedback. Suited to Microduck robots, robot joints and industrial use. View full description
  • 100% Original Products
  • GST Invoice
  • Earn 3% Cashback
₹2,342.30 inc. GST
₹1,985.00 ex. GST
22 people looking at this.

Technical Specifications

Brand:
Feetech
Rated Input Voltage:
4V-8.4V
Peak Stall Torque:
9kg.cm @ 4.8V
Stall Current:
1.2A @ 4.8V
Rated Load:
2.2kg.cm @ 4.8V
Rated Current:
500mA @ 4.8V
No-Load Speed:
0.137sec/60 degrees (73RPM) @ 4.8V
No-Load Current:
160mA or less @ 4.8V
KT Constant:
7.5kg.cm/A
Motor Type:
Coreless Motor
Gear Type:
Metal Gear
Gear Ratio:
1/320
Back Lash:
0.5 degrees or less
Bearing:
Ball Bearings
Horn Gear Spline:
25T / OD 4.95mm
Case Material:
PA66+GF43%
Size (A x B x C):
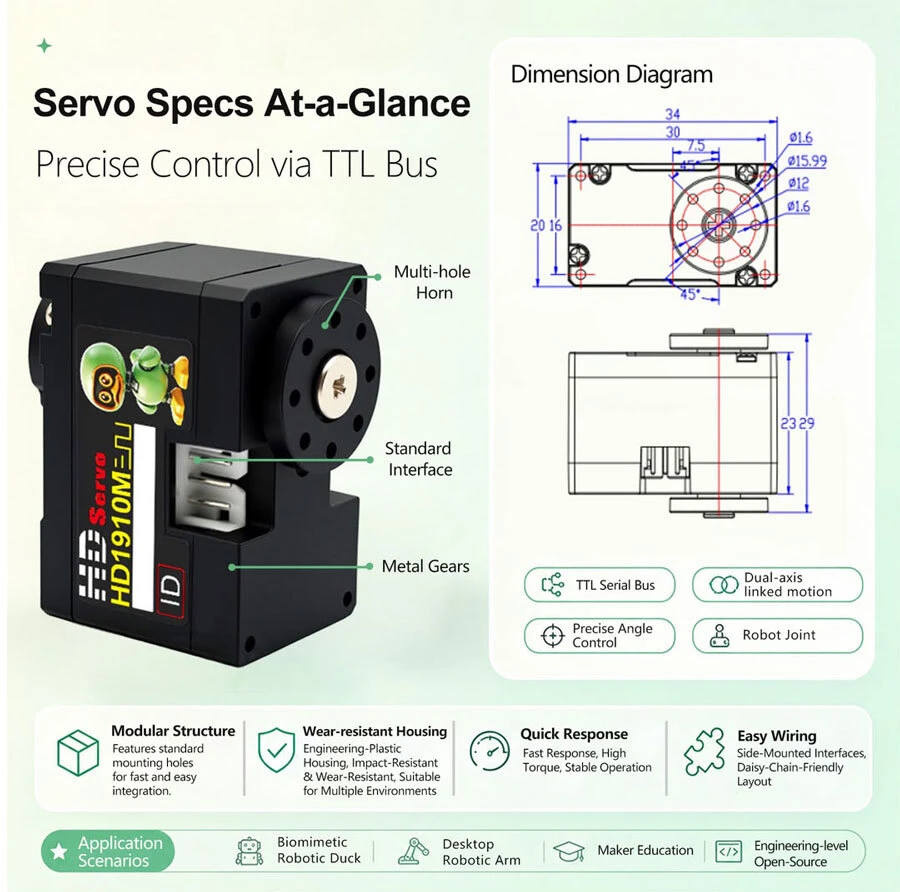
34mm x 20mm x 23mm
Weight:
21g
Connector Wire Length:
15cm
Command Signal:
Digital Packet
Protocol Type:
Half-Duplex Asynchronous Serial Communication
ID Range:
0-253
Communication Speed:
38400bps-1Mbps
Control Algorithm:
PID
Neutral Position:
2048
Running Degree:
360 degrees (0-4095)
Resolution:
0.088 degrees per pulse (360/4096)
Rotating Direction:
Clockwise (0 to 4095)
Limit Angle:
No Limit
Operating Temperature Range:
-20 to 60C

Warranty Information

All the products supplied by Evelta are genuine and original. We offer 14 days replacement warranty in case of manufacturing defects. For more details, please visit our cancellation and returns page.
Description

Resources:
Datasheet

4.8V 9kg.cm Dual-Axis TTL Serial Servo Motor with 360-Degree Magnetic Encoding for Microduck Robots

The HD-1910-C001 is a 4.8V TTL bus servo with a stall torque of 9kg.cm. It uses a coreless motor, a metal gearbox with a 1/320 gear ratio, and a PA66+GF43% plastic shell. Its 360-degree magnetic encoder gives 0.088-degree resolution (4096 steps per revolution). The servo runs on a 4V to 8.4V input and weighs only 21±2g, so it fits compact builds such as Microduck-style bipedal robots.

The servo works over a half-duplex asynchronous TTL serial bus. Up to 254 IDs (0-253) can share one line, and the communication speed ranges from 38400bps to 1Mbps. It reports position, speed, load, input voltage, current and temperature back to the controller. This feedback supports overload and over-current protection, and also suits robot joints and other high-torque drive applications.

Key Features

  • High Stall Torque: Delivers 9kg.cm of peak stall torque at 4.8V with a 1.2A stall current.
  • Coreless Motor: Gives smooth, responsive motion and a no-load speed of 0.137sec/60 degrees (73RPM) at 4.8V.
  • Metal Gearbox: The metal gears have a 1/320 ratio and a back lash of 0.5 degrees or less. Ball bearings support the output shaft.
  • 360-Degree Magnetic Encoding: Absolute position control from 0 to 360 degrees, with a resolution of 0.088 degrees per pulse.
  • Multiple Operating Modes: Angle servo mode (default), constant speed mode and constant current mode.
  • Multi-Loop Mode: Supports position control of up to +/-7 turns at the highest accuracy. The turn count is not saved after power-off.
  • Constant Force Output: Set a target torque value at address 44 and the servo holds that torque.
  • Smooth Motion Control: Offers acceleration slow start and slow stop, with PID control.
  • One-Key Middle Point Setting: The neutral position is 2048, and it can be set with a single command.
  • Full Feedback: Reports load, position, speed, input voltage, current and temperature.
  • Bus Daisy-Chaining: 254 selectable IDs on a single TTL serial line.
  • Compact and Lightweight: Measures 34mm x 20mm x 23mm and weighs 21±2g.

Applications

  • Microduck and other small bipedal or quadruped robots
  • Robotic arms, grippers and joints
  • Humanoid and educational robots
  • Industrial equipment and automation setups
  • High-torque drive applications
  • Hobby and prototyping projects needing serial bus servo control